Tiago P. Nascimento, Member, IEEE, André G. S. Conceição, and António Paulo Moreira, Member, IEEE T. P. Nascimento, and A. P. Moreira are with the Department of Electrical and Computer Engineering, Faculty of Engineering from University of Porto and INESC-Porto, Porto, 4200-465 Portugal (e-mail: tiagopn@ieee.org and amoreira@fe.up.pt). A. G. S. Conceição is with Department of Electrical Engineering, Federal University of Bahia, Salvador BA, Brazil. (e-mail: andre.gustavo@ufba.br)
ARTIGO CIENTÍFICO 10 robótica
A Modified A* Application to a Highly Dynamic Unstructured Environment ABSTRACT This paper presents an application of a modified A* path planning algorithm in a highly unstructured environment. The A* allows the robot to get to the target fast and with few collisions, avoiding obstacles that move as fast as, or even faster than the robot. Two major changes were made, the consideration of an obstacle’s safe distance (slack) and an suboptimal value K for gaining in processing time. Some simulations were made using a crowded and highly dynamic environment with twelve randomly moving obstacles. In these first simulations, a middle sized 5DPO robot was used improving the issues involving the robot in following the planned path. Index Terms – Path planning, mobile robots, obstacle avoidance, dynamic unstructured environment.
I. INTRODUCTION PATH planning algorithms form a well known area of research in mobile robotics. It’s a study that involves from a single robot movement to a group of mobile robots moving in a specific formation. Issues like static or mobile obstacles avoidance, known or unknown worlds and structured or unstructured environments and single or multiple robots’ motion are the main study cases in path planning. In
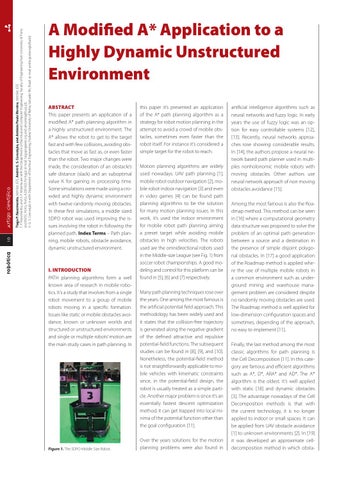
Figure 1. The 5DPO Middle Size Robot.
this paper it’s presented an application of the A* path planning algorithm as a strategy for robot motion planning in the attempt to avoid a crowd of mobile obstacles, sometimes even faster than the robot itself. For instance it’s considered a simple target for the robot to reach. Motion planning algorithms are widely used nowadays. UAV path planning [1], mobile robot outdoor navigation [2], mobile robot indoor navigation [3] and even in video games [4] can be found path planning algorithms to be the solution for many motion planning issues. In this work, it’s used the indoor environment for mobile robot path planning aiming a preset target while avoiding mobile obstacles in high velocities. The robots used are the omnidirectional robots used in the Middle-size League (see Fig. 1) from soccer robot championships. A good modeling and control for this platform can be found in [5], [6] and [7] respectively. Many path planning techniques rose over the years. One among the most famous is the artificial potential field approach. This methodology has been widely used and it states that the collision-free trajectory is generated along the negative gradient of the defined attractive and repulsive potential-field functions. The subsequent studies can be found in [8], [9], and [10]. Nonetheless, the potential-field method is not straightforwardly applicable to mobile vehicles with kinematic constraints since, in the potential-field design, the robot is usually treated as a simple particle. Another major problem is since it’s an essentially fastest descent optimization method, it can get trapped into local minima of the potential function other than the goal configuration [11]. Over the years solutions for the motion planning problems were also found in
artificial intelligence algorithms such as neural networks and fuzzy logic. In early years the use of fuzzy logic was an option for easy controllable systems [12], [13]. Recently, neural networks approaches rose showing considerable results. In [14], the authors propose a neural network based path planner used in multiples nonholonomic mobile robots with moving obstacles. Other authors use neural network approach of non moving obstacles avoidance [15]. Among the most famous is also the Roadmap method. This method can be seen in [16] where a computational geometry data structure was proposed to solve the problem of an optimal path generation between a source and a destination in the presence of simple disjoint polygonal obstacles. In [17] a good application of the Roadmap method is applied where the use of multiple mobile robots in a common environment such as underground mining and warehouse management problem are considered despite no randomly moving obstacles are used. The Roadmap method is well applied for low-dimension configuration spaces and sometimes, depending of the approach, no easy to implement [11]. Finally, the last method among the most classic algorithms for path planning is the Cell Decomposition [11]. In this category are famous and efficient algorithms such as A*, D*, ARA* and AD*. The A* algorithm is the oldest. It’s well applied with static [18] and dynamic obstacles [3]. The advantage nowadays of the Cell Decomposition methods is that with the current technology, it is no longer applied to indoor or small spaces. It can be applied from UAV obstacle avoidance [1] to unknown environments [2]. In [19] it was developed an approximate celldecomposition method in which obsta-
Note now how A* recalculates the path in order to avoid the collision points. As it can be also observed in Table I, the results made by A* are satisfactory, not only in terms of getting to the target point, but on avoiding collisions in a crowded environment that even for humans can be sometimes unavoidable.
which provided the financial and technical support for this work.
based navigation of a mobile robot in an uns-
REFERENCES
tructured environment using fuzzy logic,” in
[1]
Proceedings of the IEEE Symposium on Emerging
D. Alejo, R. Conde, J. Cobano, and A. Ollero, “Multi-UAV collision avoidance with separation
robótica
14
ARTIGO CIENTÍFICO
TABLE I. Dynamic Obstacles Result
Average Time to Reach Target
29.72s
Average Number of Collisions
3.4
The existing collisions are due to the entrapment that occurs to the robot by the moving obstacles. Therefore, the collisions became unavoidable, for the obstacles go towards the robot.
assurance under uncertainties,” in 2009 IEEE International Conference on Mechatronics, 2009,
Based Path Planning for a Multirobot System
pp. 1–6.
With Moving Obstacles,” IEEE Transactions on
VI. CONCLUSION This paper presented a new application of the grid-based path planning algorithm A* using two modifications: slack and sub-optimal K value. The first modification builds a security space around the obstacles making them bigger, while the second allows the A* to calculate a faster path making the processing time smaller. Some simulations were made using a crowded and highly dynamic environment with twelve randomly moving obstacles. The simulations were divided in two types of environments: structured and unstructured. The path planner A* built an entire path around the obstacle. In a static environment the robot passed through the obstacles avoiding them successfully. In a unstructured environment the A* algorithm had to re-plan the path to succeed in reaching the target point while avoiding the obstacles. The path construction made by A* was considerable, not only in terms of getting to the target point, but on avoiding collisions in a crowded environment.
Transaction on Systems, Man, and Cybernetics,
time robot path planning based on a modified
2007.
pulse-coupled neural network model.” IEEE tran-
[7]
[8]
[16] P. Bhattacharya and M. Gavrilova, “RoadmapBased Path Planning Using the Voronoi Diagram
141–146.
for a Clearance-Based Shortest Path,” IEEE Robo-
K.
tics & Automation Magazine, 2008.
Khantanapoka
and
K.
Chinnasarn,
“Pathfinding of 2D & 3D game real-time strategy
[17] M. Peasgood, C. M. Clark, and J. McPhee, “A Com-
with depth direction Aˆ a algorithm for multi-
plete and Scalable Strategy for Coordinating
layer,” 2009 Eighth International Symposium on
Multiple Robots Within Roadmaps,” IEEE Transac-
Natural Language Processing, 2009.
tions on Robotics, 2008.
T. P. Nascimento, C. C. Paim, and A. L. D. Costa,
[18] J. Yao, C. Lin, X. Xie, A. J. Wang, and C.-C. Hung,
“Omnidirectional Mobile Robot’s Trajectory Tra-
“Path Planning for Virtual Human Motion Using
cking Control System: A Multivariable Approa-
Improved A* Star Algorithm,” 2010 Seventh Inter-
ch,” in Congresso Brasileiro de Autom´atica, 2010,
national Conference on Information Technology: New Generations, 2010.
A. S. Conceic¸ao, A. Moreira, and P. Costa, “Prac-
[19] C. Cai and S. Ferrari, “Information-driven sensor
tical approach of ˜modeling and parameters
path planning by approximate cell decompo-
estimation for omnidirectional mobile robots,”
sition.” IEEE transactions on systems, man, and
Mechatronics, IEEE/ASME Transactions on, pp. 377
cybernetics. Part B, Cybernetics : a publication of
–381, 2009.
the IEEE Systems, Man, and Cybernetics Society,
T. P. Nascimento, A. G. S. Conceic¸ao, and A. P.
2009.
G. M. Moreira, ˜“Omnidirectional Mobile Robot’s
[20] D. Ferguson, M. Likhachev, and A. Stentz, “A Gui-
Multivariable Trajectory Tracking Control: A Ro-
de to Heuristic-based Path Planning,” in Procee-
bustness Analysis,” in 9th Portuguese Conference
dings of the International Workshop on Planning
on Automatic Control, 2010.
under Uncertainty for Autonomous Systems. Inter-
S. Yang, “Real-time torque control of nonholo-
national Conference on Automated Planning and
in Proceedings of the IEEE Internatinal Symposium
Scheduling (ICAPS), 2005, pp. 1–10. [21] J. Bruce and M. Veloso, “Safe Multirobot Naviga-
on Intelligent Control, 2002, pp. 81–86.
tion Within Dynamics Constraints,” Proceedings
K. Pathak and S. K. Agrawal, “An Integrated Path-
of the IEEE, 2006.
Planning and Control Approach for Nonholoni-
[22] P. J. Costa, “Simtwo,” 2010, available from http://
mic Unycycles Usimg Switched Local Potentials,”
paginas.fe.up.pt/paco/wiki/index.php?n= Main.
IEEE Transactions on Robotics, 2005.
SimTwo. [Online]. Available: http://paginas.
[10] K. Kurihara, N. Nishiuchi, J. Hasegawa, and K. Masuda, “Mobile Robots Path Planning Method
fe.up.pt/apaco/wiki/index.php?n=Main.SimTwo
with the Existence of Moving Obstacles,” in 2005
[23] R. Smith, “Open dynamics engine,” 2010, availa-
IEEE Conference on Emerging Technologies and
ble from http://www.ode.org. [Online]. Availa-
Factory Automation, 2005, pp. 195–202.
ble: http://www.ode.org
[11] J.-C. Latombe, Robot Motion Planning. Kluwer
ACKNOWLEDGMENT The authors would like to thank INESCPorto for the support in project ROBIS
IEEE Neural Networks Council, 2009.
Mobile Robots and Competitions, 2009, pp.
nomic mobile robots with obstacle avoidance,”
[9]
sactions on neural networks / a publication of the
thm,” in ROBOTICA 2009 -9th Conference on
pp. 1664– 1670. [6]
tions and Reviews), 2009.
Planning Considering Accelerations,” IEEE
path planning using a modified A * algori-
[5]
Systems, Man, and Cybernetics, Part C (Applica-
[15] H. Qu, S. X. Yang, A. R. Willms, and Z. Yi, “Real-
[3] P. Costa, A. P. Moreira, and P. Costa, “Real-time
[4]
Technologies, 2005., 2005, pp. 230–235. [14] H. Li, S. X. Yang, and M. L. Seto, “Neural-Network-
chical Incremental Path Planning and Motion
A*
2001, pp. 1062– 1064. [13] N. Rahman and A. Jafri, “Two layered behaviour
[2] X.-c. Lai, S. S. Ge, and A. A. Mamun, “Hierar-
Average Measurements in 30 simulations
ference on Fuzzy Systems. (Cat. No.01CH37297),
Academic Publishers, 1991.
[24] J. R. Ferreira and A. P. G. M. Moreira, “Non-linear Model Predictive Controller for Trajectory Tra-
[12] P. Tang, “Dynamic obstacle avoidance based on
cking of an Omni-directional Robot Using a
fuzzy inference and transposition principle for
Simplified Model,” in 9th Portuguese Conference
soccer robots,” in 10th IEEE International Con-
on Automatic Control, 2010.