Francisco J. Rodríguez Lera, Vicente Matellán, Miguel Á. Conde Dept. of Mechanical, Computer and Aerospace Eng., Universidad de León, Campus de Vegazana, (León), Spain Email: {fjrodl, vicente.matellan, mcong}@unileon.es Francisco Martín Rico Dept. Teoría de la Señal y Com. y Sist. Telem. y Comput., Universidad Rey Juan Carlos Fuenlabrada, (Madrid) Spain Email: francisco.rico@urjc.es
artigo científico 8
robótica 110, 1.o Trimestre de 2018
robótica
Make me different! Motivational‑based architecture for uniqueness behavior in robotics competitions ABSTRACT The use of common frameworks and open source libraries for programming robots are causing the perception that robots share the same repetitive behaviors. This is happening not only in a singular robot, sometimes even among different robots. It can be easily observed at robotic competitions, where several robots face the same tasks. Perceived behavior plays a significant role in the acceptation of robots by people. The interpretation of these behaviors by spectators is a cornerstone in order to establish some kind of human-robot attachment. This paper presents a motivational based architecture to generate more natural behaviors in autonomous robot behaviors. The outcome comes in two ways, quantitatively, the robot acts differently each loop of execution attending the motivation in that moment and qualitatively, spectators in robotics competitions perceive a new level of robot’s abilities.
1. INTRODUCTION Robotics competitions present a formal, goal-oriented environment, where the main purpose is to do tasks in a bounded window of time with the minimal number of errors. In this scenario, each team has to do their software developments in order to fulfill the tasks and face the tasks from two points of view: they are an experienced group and they have a well-defined set of libraries or they use off-the-shelve solutions with slight modifications. In both cases, the tasks are performed in the same way again and again, only changing if large environmental changes happen. In this way, spectators perceive repetition of the same behaviors.
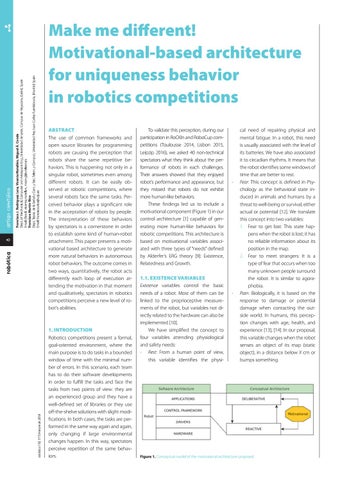
To validate this perception, during our participation in RoCKIn and RoboCup competitions (Toulousse 2014, Lisbon 2015, Leipzip 2016), we asked 40 non-technical spectators what they think about the performance of robots in each challenges. Their answers showed that they enjoyed robot’s performance and appearance, but they missed that robots do not exhibit more human-like behaviors. These findings led us to include a motivational component (Figure 1) in our control architecture [1] capable of generating more human-like behaviors for robotic competitions. This architecture is based on motivational variables associated with three types of “needs” defined by Alderfer’s ERG theory [9]: Existence, Relatedness and Growth. 1.1. EXISTENCE VARIABLES Existence variables control the basic needs of a robot. Most of them can be linked to the proprioceptive measurements of the robot, but variables not directly related to the hardware can also be implemented [10]. We have simplified the concept to four variables attending physiological and safety needs: • Rest: From a human point of view, this variable identifies the physi-
•
•
cal need of repairing physical and mental fatigue. In a robot, this need is usually associated with the level of its batteries. We have also associated it to circadian rhythms. It means that the robot identifies some windows of time that are better to rest. Fear: This concept is defined in Psychology as the behavioral state induced in animals and humans by a threat to well-being or survival, either actual or potential [12]. We translate this concept into two variables: 1. Fear to get lost: This state happens when the robot is lost; it has no reliable information about its position in the map. 2. Fear to meet strangers: It is a type of fear that occurs when too many unknown people surround the robot. It is similar to agoraphobia. Pain: Biologically, it is based on the response to damage or potential damage when contacting the outside world. In humans, this perception changes with age, health, and experience [13], [14]. In our proposal, this variable changes when the robot senses an object of its map (static object), in a distance below X cm or bumps something.
Figure 1. Conceptual model of the motivational architecture proposed.
1.3. Growth Variables Need for self-development, individual growth and advancement form this category. It defines self-actualization needs and intrinsic component of esteem needs. However, at this stage of our research, we have not included these variables in the architecture. In real-world scenarios, these variables will generate discovering behaviors at home that eventually would get it closer to the user. 1.4. Resolution, Range, and Thresholds In real world scenarios, motivational variables are implemented as a set of sensors. Each variable is defined mainly by two factors: range, and resolution. The first parameter defines maximum and minimum values applied to a variable, the second parameter defines the values to be used in a given variable.
2. INTEGRATION PROPOSAL This section summarizes the basis of our hybrid control architecture for socially assistive robots, it is inspired by the system proposed in [12] that draws a solution based on layers and motivational approach. Figure 2 depicts all the components involved in the decision making of this proposal. Data flow starts in the planner and ends as a robot action. The Planner receives a goal, which can be defined by user’s input or by robot internal scheduler. Sequencer and Executor entities trigger any of the behaviors entities available. The implementation proposed in this paper presents the planner, the sequencer and the executor as high-level component of the architecture and the behavior component as a reactive layer based on finite state machines.
2.1. Software Development We have used ROS and BICA frameworks to implement our software architecture [18]. Figure 2 presents these two frameworks fitting our architecture. We used ROS components to manage all robot features and on top of that deployed BICA which provides the behavioral and deliberative management. The ROS layer is in charge of hardware management. Sometimes ROS is presented as a meta-operating system because is halfway between an operating system and middleware. It provides the operating system services (hardware abstraction, process management, communication) and also high-level functionalities (asynchronous and synchronous calls, centralized database, robot configuration system, etc.). BICA offers a basic unit of functionality named component. Each component in the system is focused on one task. At the same time, these components can be broken down into simpler tasks. This proposal is inspired in the Brooks principles of behavior decomposition. 2.2. Variables Set up Variables used in our proposal are organized in three types depending on the nature of its value: natural and percentage variables, which have a range between 0 to 100; and time-related variables, that take values from 0 to 100. • Rest: It is a percentage variable. If the value is under 20% a warning message is raised. It depends on battery status of the robot.
Figure 2. Implementation of our hybrid architecture with motivational component using BICA and ROS.
artigo científico
1.2. Relatedness Variables Relatedness variables as Curiosity and Frustration have been historically used in robots to develop HRI behaviors [12]. These variables are used for establishing or maintaining relationships with the users. It is considered three different variables in order to provide the interpersonal needs to the robot: • Comfort represents the immediate experience of feeling strengthened when basic needs of relief, ease, and transcendence are addressed [16]). In our robot, we have associated it to the value of the Safe variable. • Curiosity models the exploratory behaviors of humans when they encounter unusual sights or sounds. The robot can generate these behaviors even in the absence of any external reward [17]. In our architecture, we use this variable to trigger new robot behaviors. • Frustration represents in humans the perceived resistance to the fulfillment of a will. This situation is measured by the robot as the results it is expecting related to the effort that it is applying for a goal.
Then, it is necessary to define the thresholds that trigger new robot behaviors. They are being defined attending two factors: robot role and users’ needs. We have modeled three robot roles: service role, (tele-operation, semi-autonomous), companion role, and autonomous assistance role. These roles have been designed to meet user’s expectations of the robot. Besides, we have added a new level of influence defining four types of robot personality: none, relaxed, brave, and timid. This defines robots’ character. It means a defined pattern of behavioral characteristics (for instance wait for interaction vs look for interaction).
9
Safeness: This one models the instinct to get protected from elements. In our robot, this variable relates fear and pain variables.
robótica
•
•
•
•
robótica
10
artigo científico
•
•
•
•
Fear to get lost: It is a time-related variable. If the robot stays more than a T time without a valid localization, a warning message is sent. Fear to strangers: It is implemented as a natural value. When the robot recognizes new faces in the environment this variable is increased. If the value is higher than the threshold (90%), a warning message is raised. Pain: It is also a natural number. If the robots get closer to an obstacle than a given threshold (i.e. 15 cm), the pain level increases one point. The event of bumping into something increases 15 units this variable. It is also decreased at a rate of 1 unit every time T (time without collisions) until it is 0. Safe: It is initialized to 0 and it is increased along the time T. Safe value is decreased by one-unit every time Pain value reaches the limit threshold. If Pain >10 then Safe variable is decreased by 1. If this value is under 20 the robot starts a warning mode, and under 10 units, a warning message is raised. This variable should be initialized at 50%, but in our case, we have proposed a non-safe start to evaluate its relevance to comfort and the influence of pain variable. Comfort: It is defined by a percentage. It is related to the Safe variable. This value decreases one unit each minute that Safe variable is in warning mode. We consider the status as okay if the value is above 50%. We start this variable with the value of 60% due to robot predefined role. Curiosity: It is a time-related variable. It depends on three states: 1) the robot stays 30 seconds without external stimuli, 2) Comfort is above 50% and 3) there is no goal. Frustration: It is a time-related variable also associated to Comfort. If the robot stays 70 seconds without, the variable increases.
These variables and thresholds are defined attending the robot rolerole, in particular, the companion role. However, in the evaluation the limits have been customized for illustrative purposes, as a result, some instinctive robot behaviors are triggered earlier. The thresholds for a long-term robot proposal (upper and lower limits) should be defined having
in mind final user aspects such as special needs or robot acceptance. • 3. EVALUATION METHOD The method to evaluate a new decision taking method is to propose a real test where the motivational architecture can impact the regular behaviors in competitions. Our setup was defined addressing the speech benchmark proposed for RoboCup@home 2016. It consists on a group of individuals surrounding the robot and asking questions, the robot has to turn and face the human who is asking. In this task, the robot scores if it turns to the human who is asking the question, which is an important factor in HRI (responsive robotic gaze). How to generate spontaneous behaviors in this scenario? It is necessary to add a new perspective in the game, for instance, if the robot knows the human who is asking. In that manner, the robot starts looking for someone (previously meet) to play the trivia game. In this way, in the absence users to play, the robot asks and wanders looking for people to interact. Once the interaction starts, there are also situations of absence of questions (or misunderstood questions) where the robot asks for continuing the game or request more questions. In this simple manner the scenario presents non-automatic behavior instead of a robot turning itself waiting for questions. Three phases illustrate the evolution of the motivational variables in this sequence of events: • The initial phase (P0) generates the set-up of the motivational variables. • The second phase (P1) presents the variables when the robot is looking for interaction. • The third phase (P2) starts when the robot finds a human who asks for starting the trivia game. This phase is split into sub-phases according to Frustration variable. Each time that Frustration increases or decreases, a new sub-phase is generated. The evolution of the existence variables during the test of 220 seconds reflects: • Rest: The robot drains 20% of the battery every 5 minutes on average. • Fear: Both variables keep the values because only previously know people takes part in the test and the
•
localization is well known the whole test. Pain: It starts to fluctuate at second 100 because during the navigation hits the sofa. Safe: The robot feels safe because its Pain variable has not exceeded the threshold, and also the Fear values remain stationary. Under these circumstances, this variable is increased linearly along the time.
This progress enables the relatedness variables which allow generating unpremeditated behaviors: • Comfort: This value does not change because the game is not played, so it remains in its original value. • Curiosity: This value increases when the robot is having any interaction with humans. After 50 seconds, the robot switches to the looking for people state (human search). When the saturation level is reached a question is formulated by the speech synthesis module: “I don’t like this. Where is everybody?”. This action decreases the variable by 10 units and the robot starts searching for humans again. This state is repeated until an individual appears or the robot reaches the saturation level in frustration variable. This situation can be depicted graphically as a sawtooth graph that has been framed in a red dotted box labeled as “Curiosity” in Figure 3. • Frustration: Negative factors associated with a given task, in this case, many attempts of interaction with no answer, trigger this variable. This time-dependent variable grows up for 140 seconds, once the saturation level is reached (second 190) the robot changes its state to robot mode. This is equivalent to take care of existence needs and activating idle mode until a new goal is received. As can be observed in the experiment, those scenarios where the interaction is crucial, each successful or unsuccessful action affects the relatedness variables, thus, alters the motivation of the robot for creating new interactive behaviors. In addition, existence variables change even in absence of actions, as predicted by Maslow and Alderfer’s proposals, in order to fulfill those existence-type variables of the robot.
robotics framework,” in Simulation, Modeling, and Programming for Autonomous Robots. Springer, 2010, pp. 251–262. [8] Seib, V., Manthe, S., Holzmann, J., Memmesheimer, R., Peters, A., Bonse, M., ... & Shah, U. (2015). Robocup 2015-homer@ unikoblenz (Germany). RoboCup@ Home League Team Descriptions for the Competition in Hefei, China. [9] C. P. Alderfer, “An empirical test of a new theory of human needs,” Organizational behavior and human performance, vol. 4, no. 2, pp. 142–175, 1969. [10] T. Nomura, T. Uratani, K. Matsumoto, T. Kanda, H. Kidokoro, Y. Suehiro, and S. Yamada, “Why do children abuse robots?” in Proceedings of the Tenth Annual ACM/IEEE International Conference on Human-Robot Interaction Extended Abstracts. plus 0.5em minus 0.4emACM, 2015, pp. 63–64. Figure 3. Evolution of motivational variables.
[11] R. C. Arkin, M. Fujita, T. Takagi, and R. Hasega-
REFERENCES
2003.
[1] F.J. Rodríguez-Lera, V. Matellán, M.A. Conde,
[12] F. J. R. Lera, “Design, fabrication, and validation of
and F. Martín-Rico. “A motivational architecture
a socially assistive robot based on augmented
to create more human-acceptable assistive
reality,” Ph.D. dissertation, University of León, De-
robots for robotics competitions”. IEEE Inter-
cember 2015.
national Conference on Autonomous Robot
[13] T. Steimer, “The biology of fear-and anxiety-
Systems and Competitions (ICARSC’2016), 4-6
related behaviors,” Dialogues in clinical neurosci-
May 2016. Bragança (Portugal). DOI: 10.1109/ ICARSC.2016.19. [2] D. Nardi, J.-D. Dessimoz, P. F. Dominey, L. Iocchi, P. Rybski, J. Savage, S. Schiffer, T. Wisspeintner, T. van der Zant, and A. Yazdani, “Robocup@ Home–Rules and Regulations,” 2008.
ence, vol. 4, no. 3, p. 231, 2002. [14] H. E. Merskey, “Classification of chronic pain: Descriptions of chronic pain syndromes and definitions of pain terms.” Pain, 1986. [15] M. P. Jensen and D. C. Turk, “Contributions of psychology to the understanding and treat-
[3] L. Mudrova, M. Chiou, M. Becerra, S. Bastable,
ment of people with chronic pain: Why it mat-
J. Smith, E. Bacci, T. Daskova, and A. Hristova,
ters to all psychologists.” American Psychologist,
“Rockin TDP: Birmingham Autonomous Robotic Club (BARC),” School of Computer Science, Tech. Rep., 2015.
vol. 69, no. 2, p. 105, 2014. [16] J. L. A. Apóstolo and K. Kolcaba, “The effects of guided imagery on comfort, depression,
[4] J. Bohren and S. Cousins, “The Smach high-
anxiety, and stress of psychiatric inpatients
level executive [ROS news],” Robotics & Auto-
with depressive disorders,” Archives of psy-
mation Magazine, IEEE, vol. 17, no. 4, pp. 18–20,
chiatric nursing, vol. 23, no. 6, pp. 403–411,
2010.
2009.
[5] A. Mateus, J. Mendes, J. O’Neill, M. Braga, P. San-
[17] G. Stojanov, A. Kulakov, and D. Clauzel, “On curi-
tos, and R. Ventura, “Socrob@home: Team
osity in intelligent robotic systems,” in Proceed-
description paper for the competition event
ings AAAI 2006 Fall Symposium on Interaction
rockin@home 2015,” Instituto Técnico, Tech.
and Emergent Phenomena in Societies of Agents,
Rep., 2015.
Arlington, Virginia. AAAI Press, Cambridge, 2006,
[6] P. Bustos, L. Manso, M. A. Gutiérrez, M. Haut,
pp. 183–189.
M. Paoletti, I. García-Varea, J. Martínez-Gomez,
[18] J. Cañas, F. Martín, C. Aguero, E. Perdices,
L. Rodríguez-Ruíz, A. Romero-Garcés, and
V. Matellán, J. García, F. Rodríguez, D. Puig,
R. Marfil, “Rockin TDP: Ursus team,” Extremad-
T. Gonzalez, and J. Cristiano, “Spiteam’s team de-
ura, Málga y Castilla la Mancha., Tech. Rep., 2015. [7] L. Manso, P. Bachiller, P. Bustos, P. Núñez, R. Cintas, and L. Calderita, “Robocomp: a tool-based
scription paper for robocup-2011,” 2011. [19] R. A. Brooks, “A robust layered control system for a mobile robot,” Robotics and Automation, IEEE Journal of, vol. 2, no. 1, pp. 14–23, 1986.
11
tonomous Systems, vol. 42, no. 3, pp. 191–201,
4. CONCLUSIONS AND FURTHER WORK There are several challenges related to the different control architectures applied in robotics competition. We have proposed an architecture based on the hybrid approach which takes into account deliberative and reactive behaviors plus a motivational system. Our contribution defines the robot motivational variables attending the Alderfer’s organization of human inner needs. These variables modify robot behaviors and provide a mean to generate more sociably behaviors in the robot. Our experiments present changes in the finite state machine proposed for achieving the task. These changes are generated by the user interaction, and the evolution of our group of variables. Currently, we are improving the architecture behavior focused on HRI perception: • Human-like behaviors: We need to measure how a non-technical user perceives the robot behaviors. • Target group analysis: All the social behaviors generated in our control architecture were defined generically. This implies that the robot’s actions occur denatured attending the different human groups (elderly, adults or children). • We should test the architecture performance on a different set of problems in a long-term assistive experience.
robótica
human–robot interaction,” Robotics and Au-
artigo científico
wa, “An ethological and emotional basis for