
Prepare Launch 1
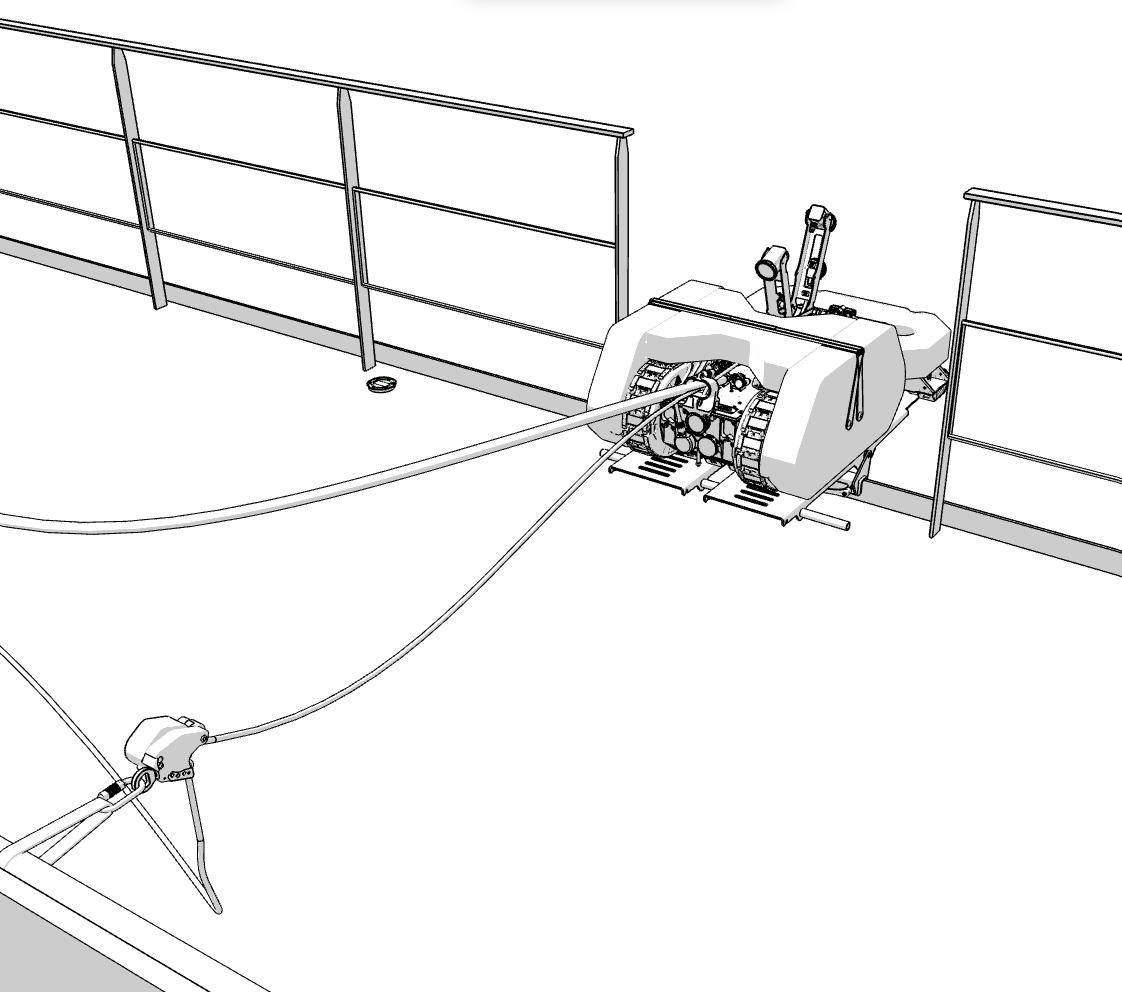
Use the static rope to secure the launch
Secure the drill powered ascender/descender [BOX0011], to the deck with the sling in the [LA00002].
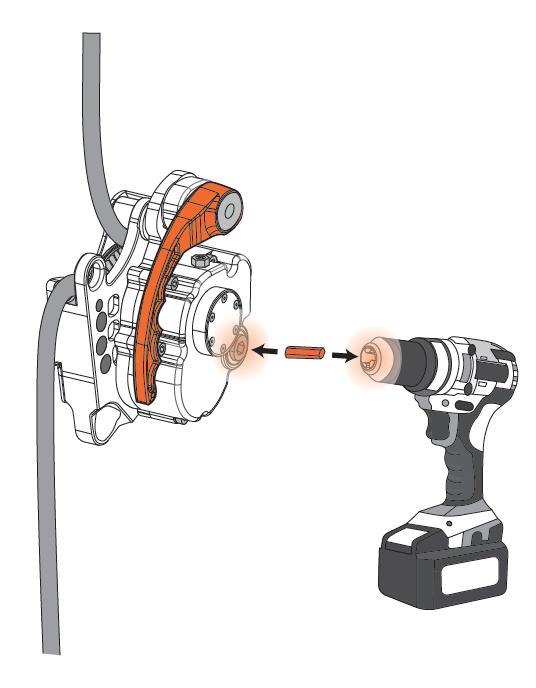
Mount the static rope to the drill powered ascender/descender.
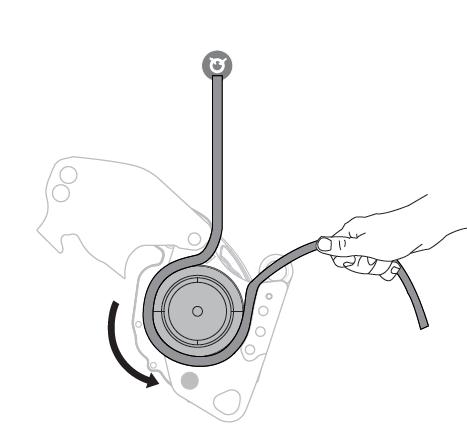
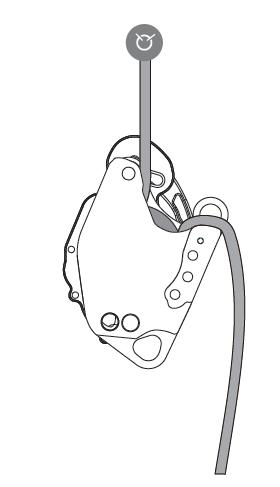
Secure the platform lift with controlled veering
Close the drill powered ascender/descender. It is now secured for operation.
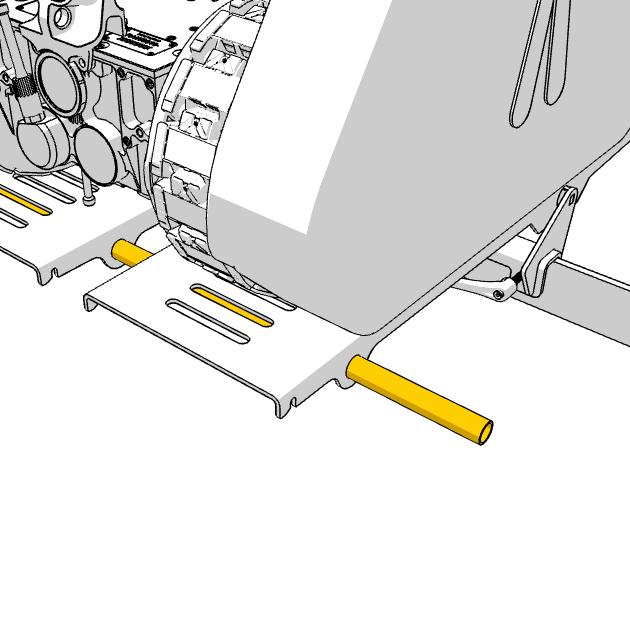
Drive the robot on the launch platform and use the steel rod (located on the Cage) to lift the Launch Platform, including the robot.
NOTE: This is a three person job. 1 to control the descender, 2 for lifting.
Release the handle on the drill powered ascender/descender [BOX0011] to facilitate veering of the rope. Immediate braking of the descend will happen, if the handle on the descender is released.
While veering the static rope, slowly lift the platform to ensure a safe launch.
After the robot has been driven on to the hull securely, the static rope is dismounted from the descender and rigged on to the winch again.
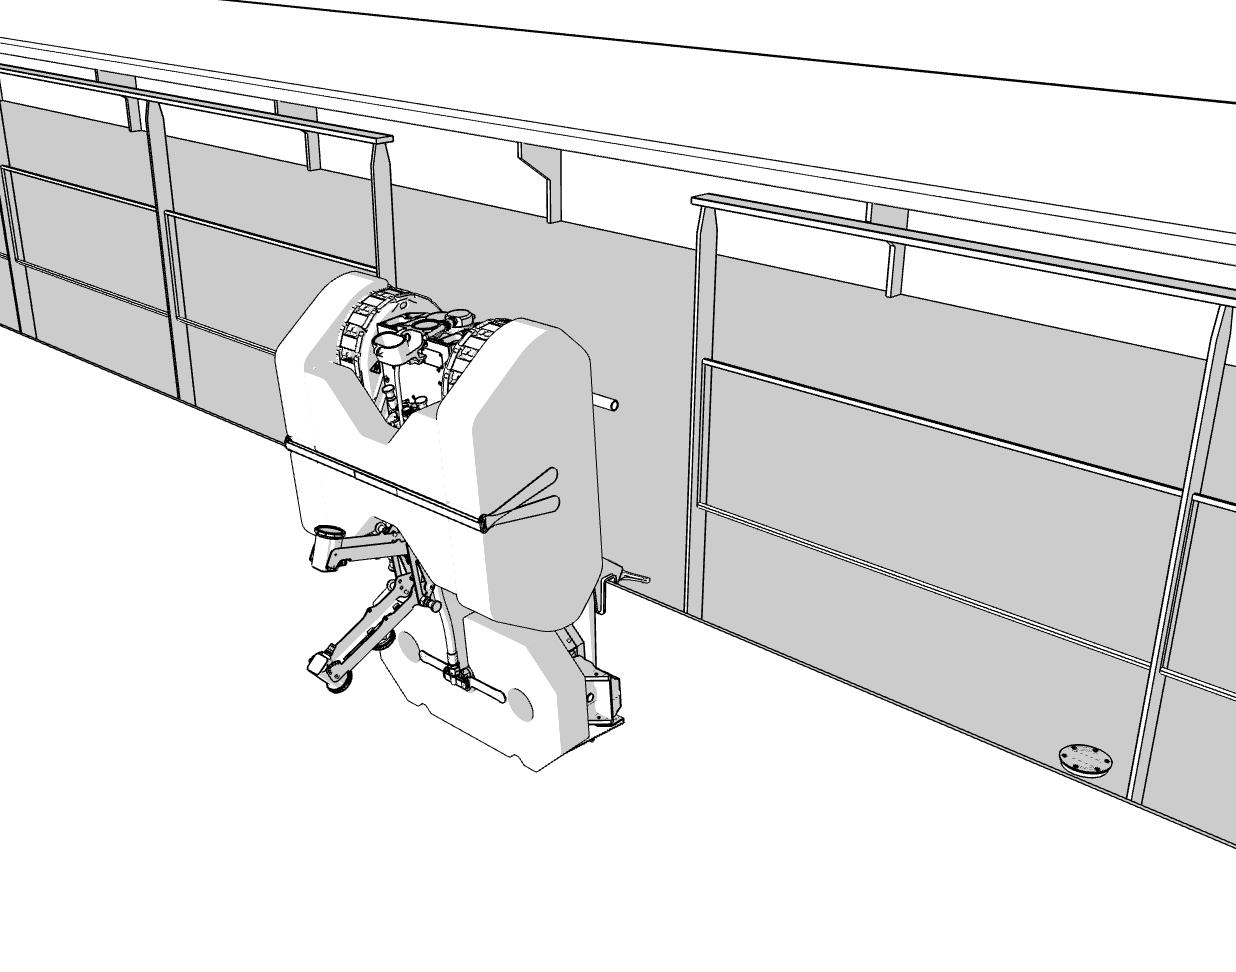
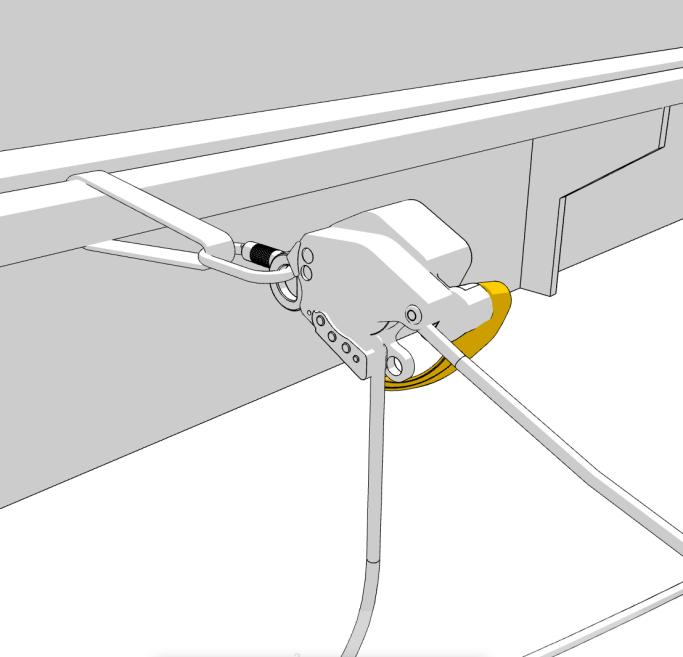
Prepare and Retrieve
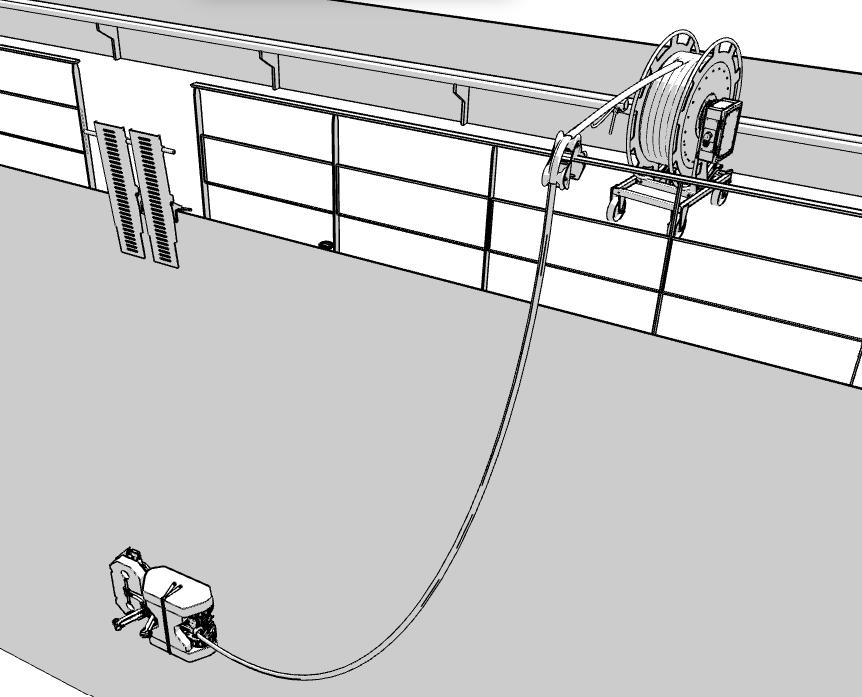
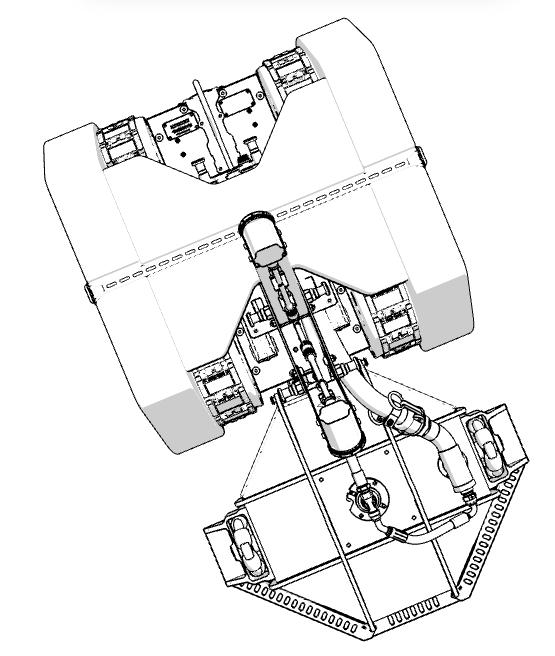
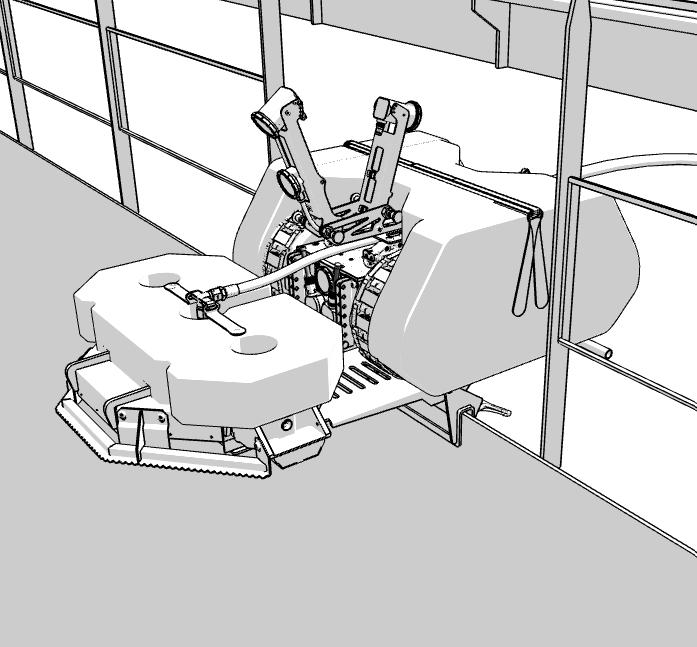
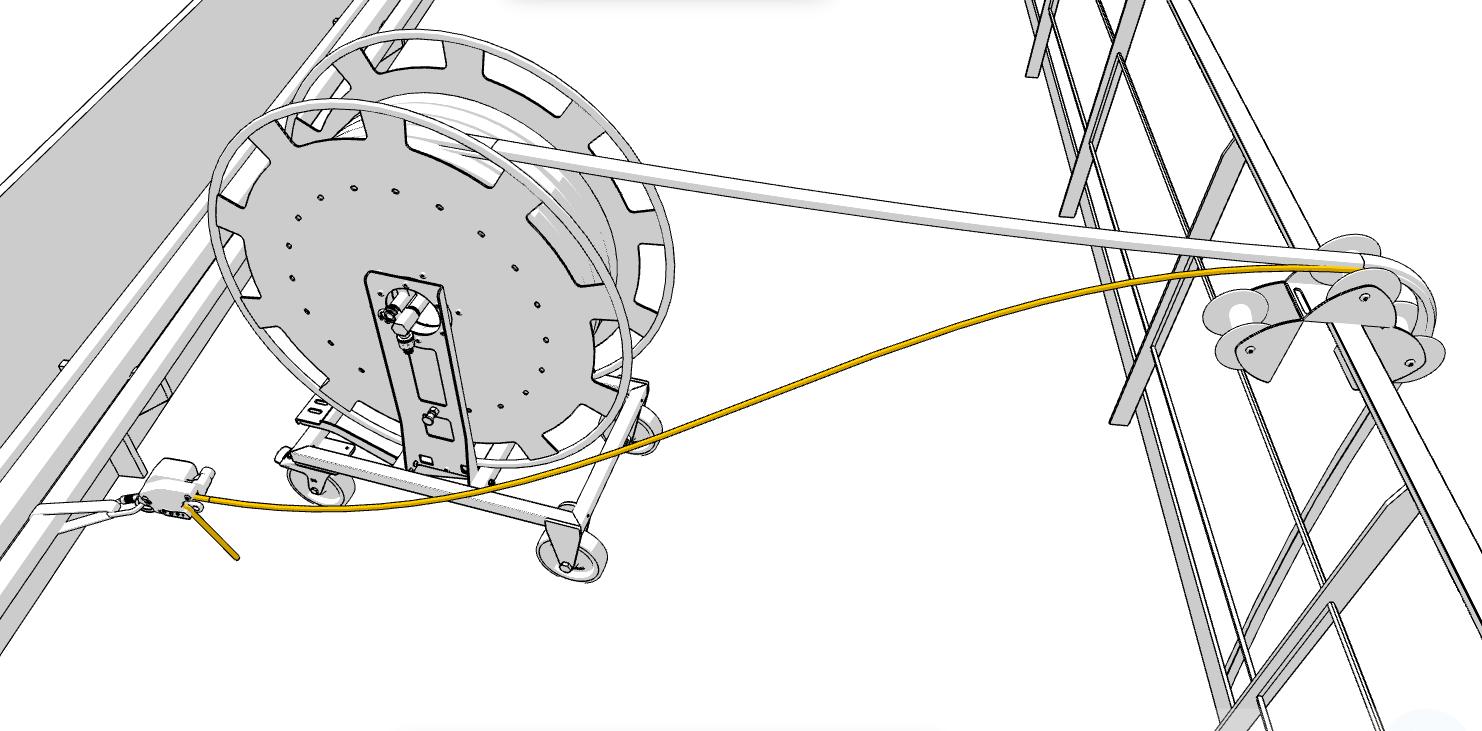
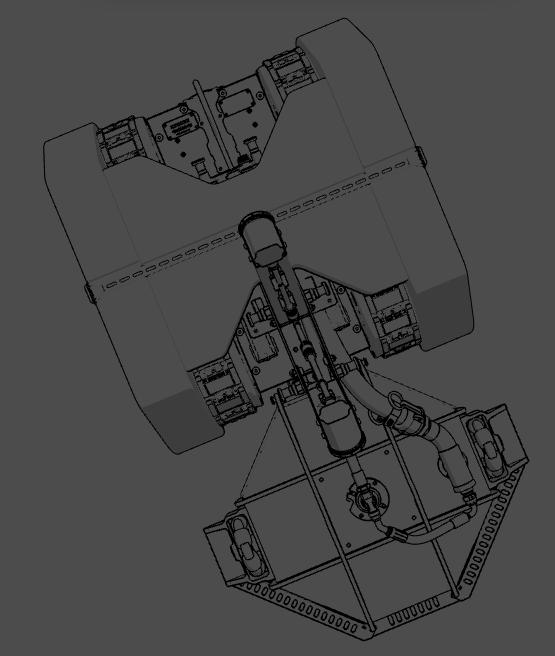
Move the cable 3-link protector to the launch area before starting the retrieval and turn off power.
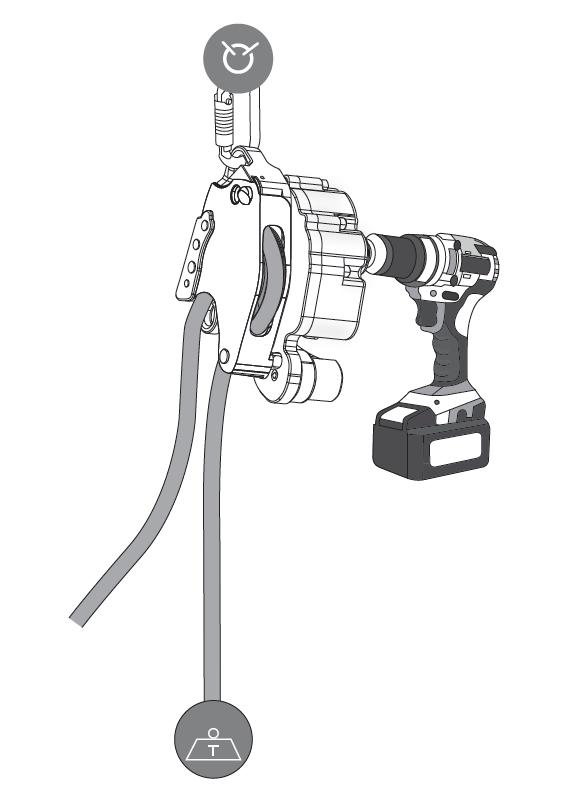
Secure the drill powered ascender/descender [BOX0011], to the deck with the sling in the [LA00002].
Separate the static rope from the winch to the drill powered ascender/descender.
Mount the static rope to the drill powered ascender/descender and use a high torque power drill to retrieve the robot. (Power drill not included). The [BOX0011] is geared 12:1 and will function as a small deck crane.
Use the drilling machine on the safety power lift to retract the robot to the launch area. OBS! Carefully manage the robot cables and hoses.
When the robot is pulled on to the launch ramp, the ramp is flipped and the system is recovered.